
This post is part of my onlone book Linear Actuator Motion Control per CAN Bus.
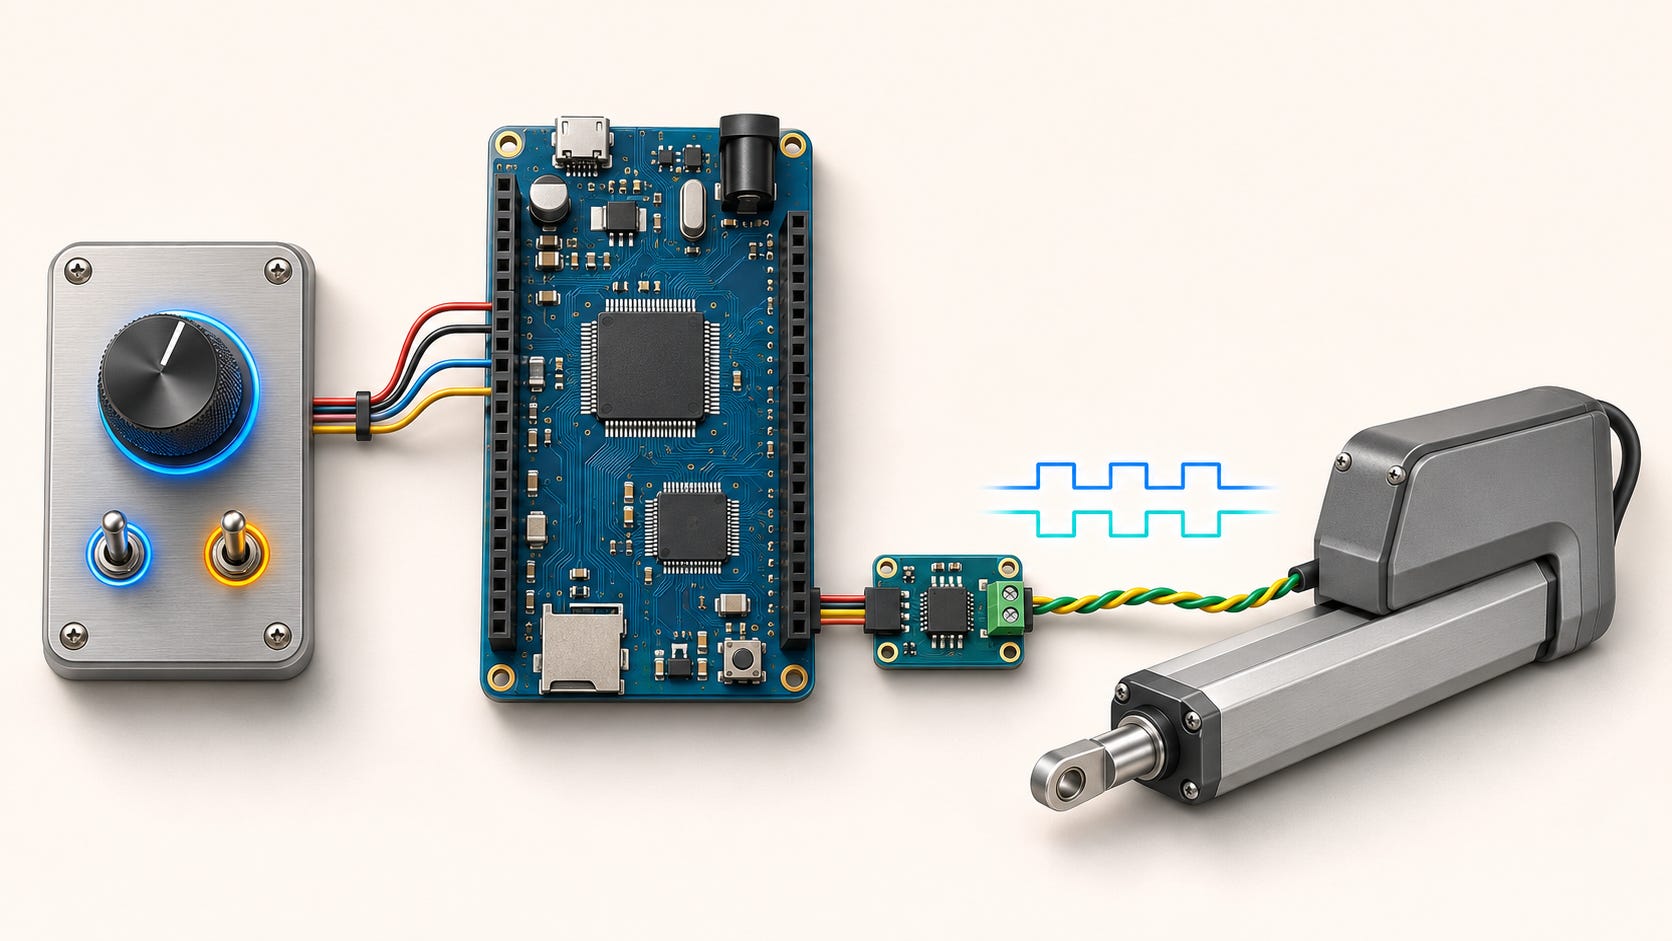
The Thomson Electracâ HD supports two modes to control the motion:
1. Manual Control - You can control the actuators merely with hardware switches (Start, Stop, Forward Motion, Backward Motion).
2. Software Control - In addition to the manual control capabilities, the CAN protocols allow to regulate the linear speed.
The Manual Control is straightforward and doesn’t require a lot of explanation. The real work starts when you need to control the linear speed per software.
The following sub-chapters are:
Manual Control
Software Control
Safety Considerations
Testing Approach
Get Your Copy—Available as Ebook or Kindle