

This article is part of CAN Bus Embedded Development, my growing online book about practical CAN Bus hardware, software, and embedded system development.
View the complete Table of Contents →
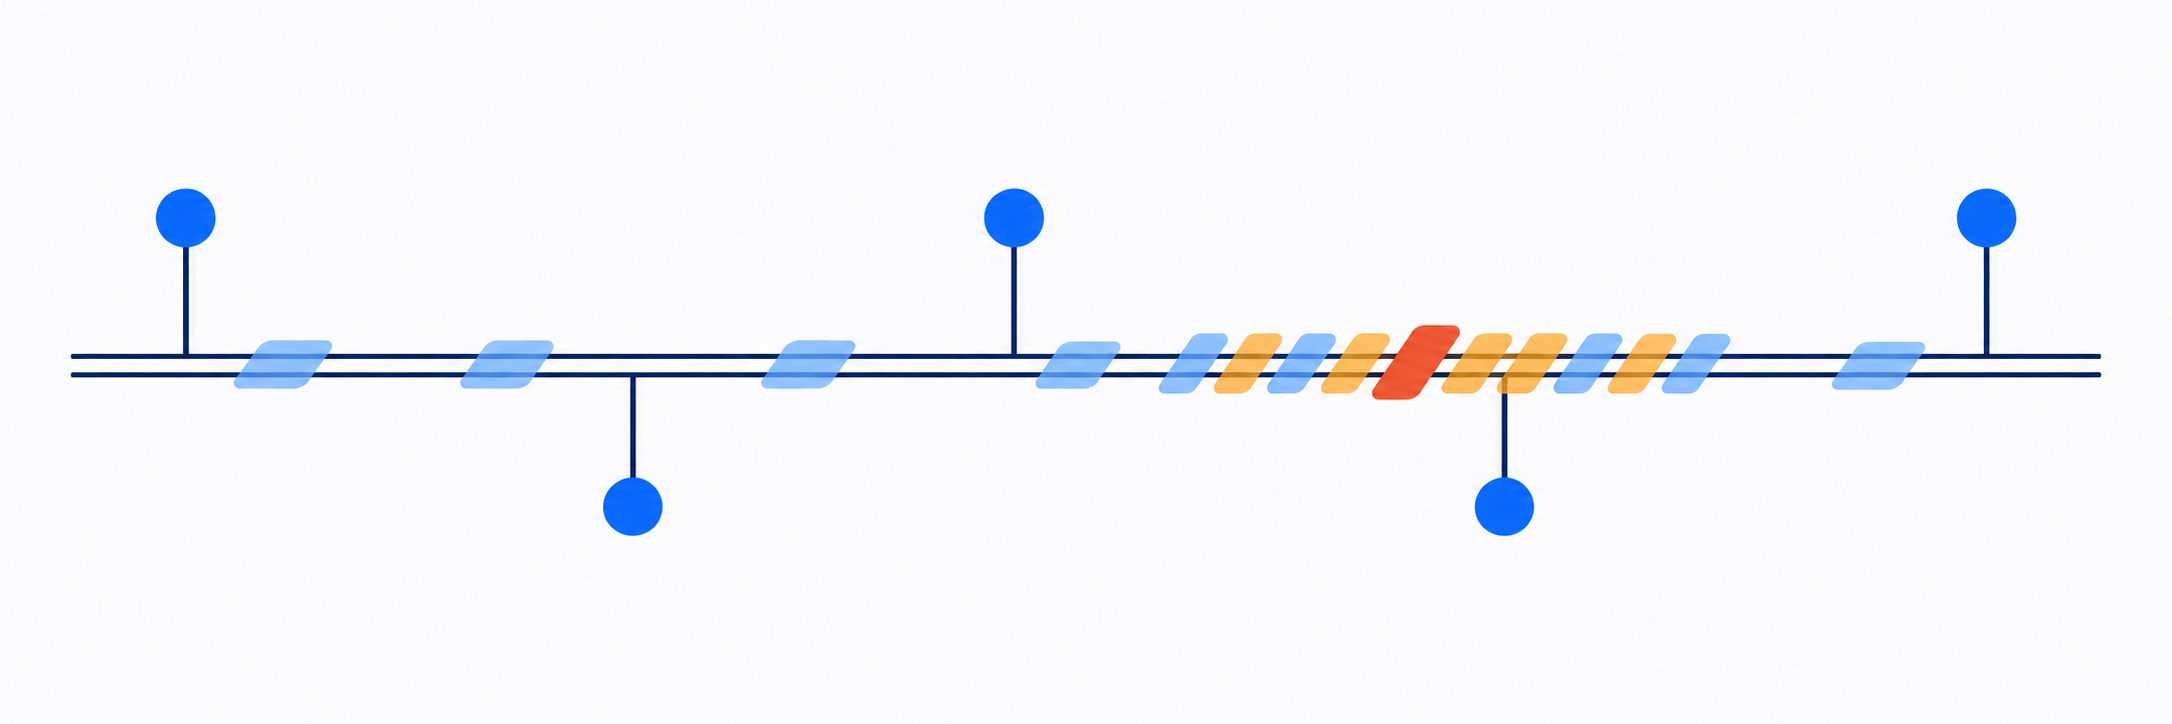
In my experience, many developers underestimate how much CAN errors can affect busload. CAN is designed to detect transmission errors and recover from them automatically. That recovery can hide a problem from the application. A message may still arrive with the correct data, but it may arrive late, and the bus may have spent considerably more time delivering it than expected.
When an established CAN network starts producing recurring error frames, I check the wiring, connectors, and termination first. When testing a new node, I verify those same things before connecting it, so I have a known-good network to work with.
